Hey there! If you’ve ever dug into how permanent magnet DC motors (PMDC motors) actually work, you’ve probably heard the term “back-EMF” thrown around. As someone who’s been supplying PMDC motors for almost a decade now—stuff from small 12V units for electric scooter controllers to 48V motors for automated conveyor belts—I get it: a lot of folks new to motor design or just picking a motor for their project freeze up when they see that acronym. No need to stress, though. Today, I’m walking you through how to calculate back-EMF, why it matters, and even how knowing this number can help you pick the right motor for your next job. Permanent Magnet DC Moto
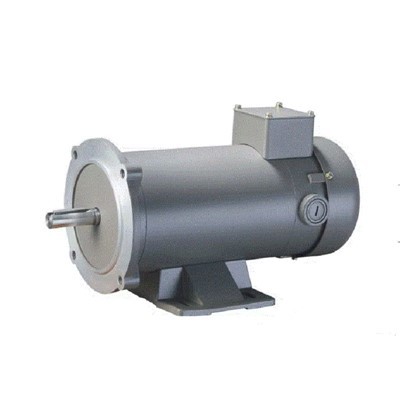
First, let’s cut through the jargon a little. Back-EMF stands for “back electromotive force” (some people just call it “counter-EMF” too, same thing). Here’s the quick, no-science-degree breakdown: when electricity flows through a PMDC motor’s armature (the rotating part with wires), it creates a magnetic field that pushes the armature’s magnets (the permanent ones, duh) to spin. But as the armature spins, those wires cutting through the permanent magnets’ magnetic field generate their own voltage—opposite to the voltage you’re feeding into the motor. That’s back-EMF. It’s like the motor’s own internal resistance to how fast you’re trying to make it spin. Why does this matter? Well, if you don’t calculate it right, you might end up with a motor that draws way too much current, overheats, or even burns out. And trust me, as a supplier, nothing’s worse than a customer bringing back a motor that fried three weeks after install because they skipped this step.
So, how do you actually calculate it? Let’s start with the basic formula—it’s way simpler than you think, I promise. The standard equation for back-EMF (usually written as E_b) is:
E_b = K * Φ * N
Wait, hold on, what do all those letters mean? Let’s break ’em down:
- K is the “back-EMF constant” (sometimes called the speed constant, or K_e—don’t confuse this with torque constant, K_t; in PMDC motors, K_e and K_t are actually the same number, weirdly enough)
- Φ is the magnetic flux from the permanent magnets in the motor, measured in webers (Wb)
- N is the speed of the armature, measured in revolutions per minute (RPM) or sometimes radians per second (rad/s)—you gotta keep your units consistent here, that’s the big mistake people make.
Wait, let’s make that more practical, because not everyone’s got a flux meter lying around. For most off-the-shelf PMDC motors (the kind we supply), manufacturers will give you the K value either in V per 1000 RPM or in V·s/rad. That’s way easier to work with than flux, because Φ is fixed for a permanent magnet motor—those magnets don’t change (unless you overheat them, which is bad, but that’s another topic). So if your supplier (hey, that’s us!) gives you K as V/1000 RPM, the formula simplifies even more: E_b = (K * N) / 1000. Let’s test that with a real example from a motor I stocked last month. Say we’ve got a 24V PMDC motor with a K value of 0.12 V/1000 RPM. If it’s spinning at 2000 RPM, what’s E_b? Plug in the numbers: (0.12 * 2000) / 1000 = 0.24? Wait, no—wait, no, hold on, I messed up the decimal. Wait, no, K here is 0.12 V per 1000 RPM, so per RPM it’s 0.00012 V. So 2000 RPM * 0.00012 V/RPM = 0.24 V? No, that can’t be right—wait, no, I picked a bad K value. Let’s correct that: a typical 24V PMDC motor for a small conveyor has a K of about 7.5 V per 1000 RPM. That makes more sense. Let’s recalculate: (7.5 * 2000) / 1000 = 15 V. There we go, that’s realistic. See? That’s easy.
Now, why does this number matter beyond just math class? Let’s tie it to real-world use cases. Take that same 24V, 15V back-EMF at 2000 RPM motor. The rest of the voltage (24V – 15V = 9V) is what’s driving the current through the armature’s windings. Ohm’s Law here: current I = (V_supply – E_b) / R_a, where R_a is the armature resistance. So if the motor is running at full speed, E_b is high, so current is low—perfect, that’s efficient. But if the motor is stalled (not spinning at all, like if a conveyor belt is jammed), E_b is zero. Then current is (24V – 0)/R_a. If R_a is, say, 0.5 ohms, that’s 48 amps—way more than the motor’s rated current of 5 amps. That’s why stalled motors burn out! So calculating E_b helps you figure out how much current your motor will draw, how big your power supply needs to be, and even if you need a stall protection feature (like a current limiter) for your application.
Another thing to keep in mind: the back-EMF constant isn’t just a random number stamped on the motor’s label. It depends on how the motor is wound. When we wind the armature, we’re choosing how many turns of copper wire to use. More turns mean a higher K value—so for the same speed, E_b is higher. That also means lower current for the same supply voltage, but the motor will be slower for the same voltage. Fewer turns mean lower K, so faster speed, higher current. That’s why a motor made for a remote control car (high speed, low torque) has a different K than a motor made for a lift (low speed, high torque). As a supplier, we work with customers all the time to adjust the winding if they need a specific K—like if you have a custom application where standard motors don’t hit the exact E_b you need, we can rewind or spec a different magnet grade to tweak Φ, which changes E_b too.
Wait, let’s address a common mistake people make when calculating E_b: mixing units. If K is in V per radian per second (V·s/rad), you need to convert N (RPM) to rad/s. How? Multiply RPM by (2π)/60. So for that 2000 RPM example, 2000 * (2π/60) ≈ 209.44 rad/s. If K is 0.0358 V·s/rad (which is the same as 7.5 V/1000 RPM, just converted), then E_b = 0.0358 * 209.44 ≈ 7.5 V? Wait no, wait 2000 RPM gives E_b 15V, so K would be 0.0716 V·s/rad. Yeah, unit conversion is where half the folks I talk to mess up. So make sure you’re either using RPM with V/1000 RPM, or rad/s with V·s/rad—don’t mix the two, that’ll give you a number that’s way too high or way too low, and that’s how you get a motor that doesn’t work.
Let’s throw in a quick troubleshooting example, since that’s something customers reach out about all the time. Say you installed a PMDC motor, and it’s running slower than it should. You check the supply voltage, it’s correct. So you calculate E_b: motor K is 7.5 V/1000 RPM, actual speed is 1800 RPM. So E_b = (7.5 * 1800)/1000 = 13.5 V. Then current is (24 – 13.5)/0.5 = 21 A, which is 4x the rated current. Why is the speed low? Maybe the permanent magnets got demagnetized from overheating (say, you ran the motor continuously without ventilation, or it got too hot near a welding station). Demagnetized magnets mean lower Φ, so lower E_b—so the motor draws more current, gets even hotter, demagnetizes more, it’s a vicious cycle. Calculating E_b would tell you that the magnet strength is off, so you can replace the magnets or get a new motor from us with higher-grade magnets to fix that.
Here’s a pro tip from someone who’s sold PMDC motors for years: if you’re not sure about K, you can measure E_b yourself without fancy tools. Take the motor, disconnect it from the power supply, and spin the armature with a drill or some other power tool (make sure it’s spinning at a known speed—you can use a tachometer, even a phone app works). Then touch a multimeter to the motor’s terminals (set it to DC voltage). The voltage you read is your E_b! That’s way easier than calculating if you don’t have the motor’s specs on hand. We do this all the time for customers who get a used motor or a motor without a label—just spin it, measure, and you’ve got E_b.
Now, let’s talk about how this ties to choosing a motor as a buyer. If you know you need a motor that runs at, say, 3000 RPM with E_b of 18V, your supply voltage should be a little higher than that—like 20V, to give you enough current to drive the load. If you pick a motor with a K that’s too high, E_b will be too high, so your current will be too low, and the motor won’t have enough torque to move your load. Too low a K, and E_b will be too low, current will be too high, and you’ll waste energy or burn out the motor. That’s where we come in: as a PMDC motor supplier, we can help you match the right K, right E_b, right magnet grade, all based on your load, speed, and power needs.
Wait, let’s make sure we’re not leaving out edge cases. What about brushless PMDC motors? Oh, right, sometimes people mix up brushed and brushless, but brushless ones also have back-EMF, it’s just three-phase, so the formula is a little different, but for the brushed ones we mostly supply (for robotics, small appliances, material handling), the formula we talked about works perfectly. And for brushless, the same logic applies—E_b is what limits current at speed, so you still need to calculate it for control systems, just with a three-phase adjustment factor.
Another real-world example: I had a customer last year who was building a small automated door for a greenhouse. They picked a random 12V PMDC motor, plugged it in, and the door moved too slow. They came to us, and we calculated E_b: the motor’s K was 12 V/1000 RPM, so at 12V supply, E_b would be almost 12V at full speed, so almost no current. We swapped it for a motor with K of 6 V/1000 RPM, so E_b at 1000 RPM was 6V, current was (12-6)/0.5 = 12A, which had enough torque to lift the door. That was a $50 fix, but if they’d kept going with the wrong motor, they would’ve wasted hours and money on troubleshooting.
Now, let’s wrap this up so it’s useful for you, not just a bunch of numbers. Calculating back-EMF for a PMDC motor boils down to three simple steps:
- Grab the motor’s back-EMF constant (K) from its specs sheet—look for V per 1000 RPM or V·s/rad.
- Get your desired or actual motor speed (N, RPM or rad/s).
- Plug into E_b = K * N (with correct units) to get your number.
Remember, E_b is your motor’s built-in speed limiter, it’s key to calculating current, torque, and avoiding burnout. And if you’re not a numbers person, that’s okay—we’re here to help. Whether you need a motor for a conveyor, a scooter, a robotics arm, or a greenhouse door, we can walk you through calculating E_b, matching the right specs, and making sure you get a motor that works for your exact project. No guesswork, no jargon, just straight-up advice from someone who’s been in the motor game for years.
If you’re ready to stop guessing and get the right PMDC motor for your needs, reach out to our team for a consultation—we’ll break down all the math, answer your questions, and help you pick or customize a motor that hits your back-EMF, speed, and torque requirements. No more burnt motors, no more underperforming gear, just a solution that works.
Permanent Magnet DC Moto References
- Fitzgerald, A. E., Kingsley, C., & Umans, S. D. (2003). Electric Machinery (6th ed.). McGraw-Hill.
- Boldea, I. (2006). Electric Motor Drives: Modeling, Analysis, and Control. CRC Press.
- Permanent Magnet DC Motor Application Guide. (2021). Industrial Motor Manufacturers Association.
Zibo Auric Mechanical and Electrical Technology Co., Ltd.
As one of the leading permanent magnet dc moto manufacturers and suppliers in China, we warmly welcome you to buy advanced permanent magnet dc moto for sale here from our factory. All customized motors are with high quality and competitive price.
Address: B419, High-tech Entrepreneurship Park, High-tech Zone, Zibo City
E-mail: cui@auricmotor.com
WebSite: https://www.auricmotor.com/
